
The PolyU Research Institute for Artificial Intelligence of Things (RIAIoT) awarded HK$800,000 to Robust Seamless Vehicle Positioning Across Road-to-Parking Transitions via Multimodal Sensor Fusion, led by Li-Ta Hsu as PI. The award was approved on 21 September 2026.
The project investigates how multimodal sensor fusion can maintain reliable vehicle positioning through open roads, entrance zones, ramps and covered parking environments. It aims to develop a positioning workflow and evaluation approach for these transitions.
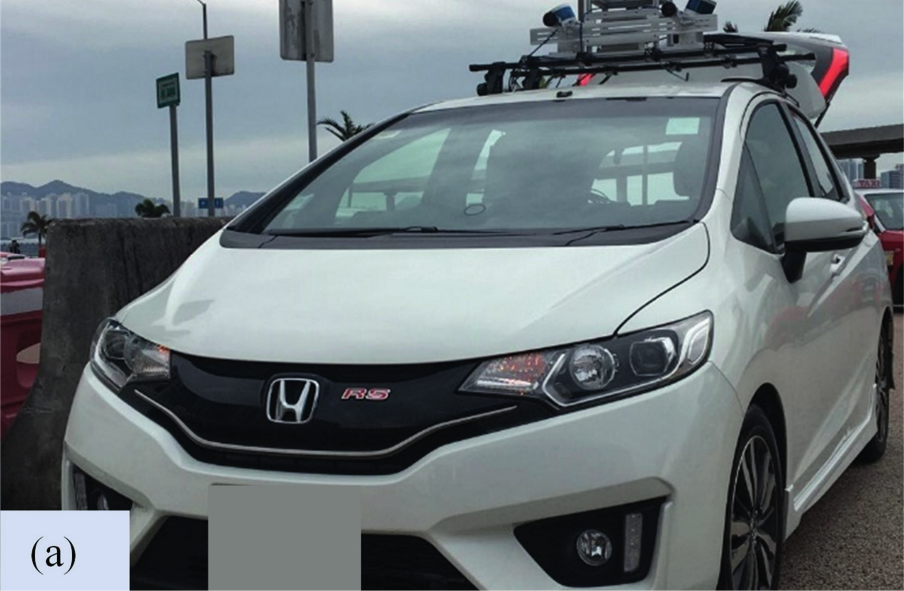
Existing UrbanNav research platform. Vehicle photograph from Figure 2 of the UrbanNav dataset paper.
Planned duration. Twelve months. The award announcement does not establish the final calendar start and end dates.
Research connection. Seamless Multi-Sensor PNT for Embodied Systems.
Funding: PolyU RIAIoT Seed Fund (HK$800k awarded September 2026; PI)